Heewon Lee
I'm a robotics engineer building robots that can understand and interact with people — with a focus on Physical AI and human–robot interaction.
More about me Less
I earned my Bachelor of Engineering in Robotics (Intelligent Systems Major) from Kwangwoon University, and now work as a Forward Deployed Engineer on the Robotics Deployment team at RLWRLD. There I've been the technical lead for several end-to-end robot deployments, owning the full pipeline from data collection and Vision-Language-Action (VLA) model training to on-stage operation. Beyond the demos, I build the teleoperation systems and tooling that bring new robot platforms online. Before RLWRLD, I interned on the AI Software team at ROBOTIS.
- Physical AI
- Imitation Learning
- Vision-Language-Action (VLA)
- Human-Robot Interaction
Experience
RLWRLD — Forward Deployed Engineer Intern · Robotics Deployment
Jan 2026 – Jun 2026
- Technical lead for the RLDX-1 launch (“Dexterity Night”) — built a multi-task VLA model reaching >95% task success from ~5 hours of demonstration data [article]
- Trained a grasping model on 200 demonstration episodes to a 100% zero-shot grasp success rate, demoed live to investors in San Francisco
- Led the RB-Y1 robot demo (manipulation + voice interaction) at the Microsoft AI Tour [article]
- Brought up and built teleoperation systems for 5 robot platforms (RB-Y1, OpenArm, OMY, AI Worker, Big YAM)
Publications
RLDX-1 Technical Report [PDF]
Dongyoung Kim, Huiwon Jang, …, Heewon Lee, …, Jinwoo Shin
arXiv preprint arXiv:2605.03269 [cs.RO]
Development of an AI-Based Assistive Eyewear System for Safe Walking of the Visually Impaired [PDF]
Yeho Shin, Minju Kwon, Heewon Lee, Yesop Lee
2025 40th ICROS Annual Conference (Institute of Control, Robotics and Systems)
Projects
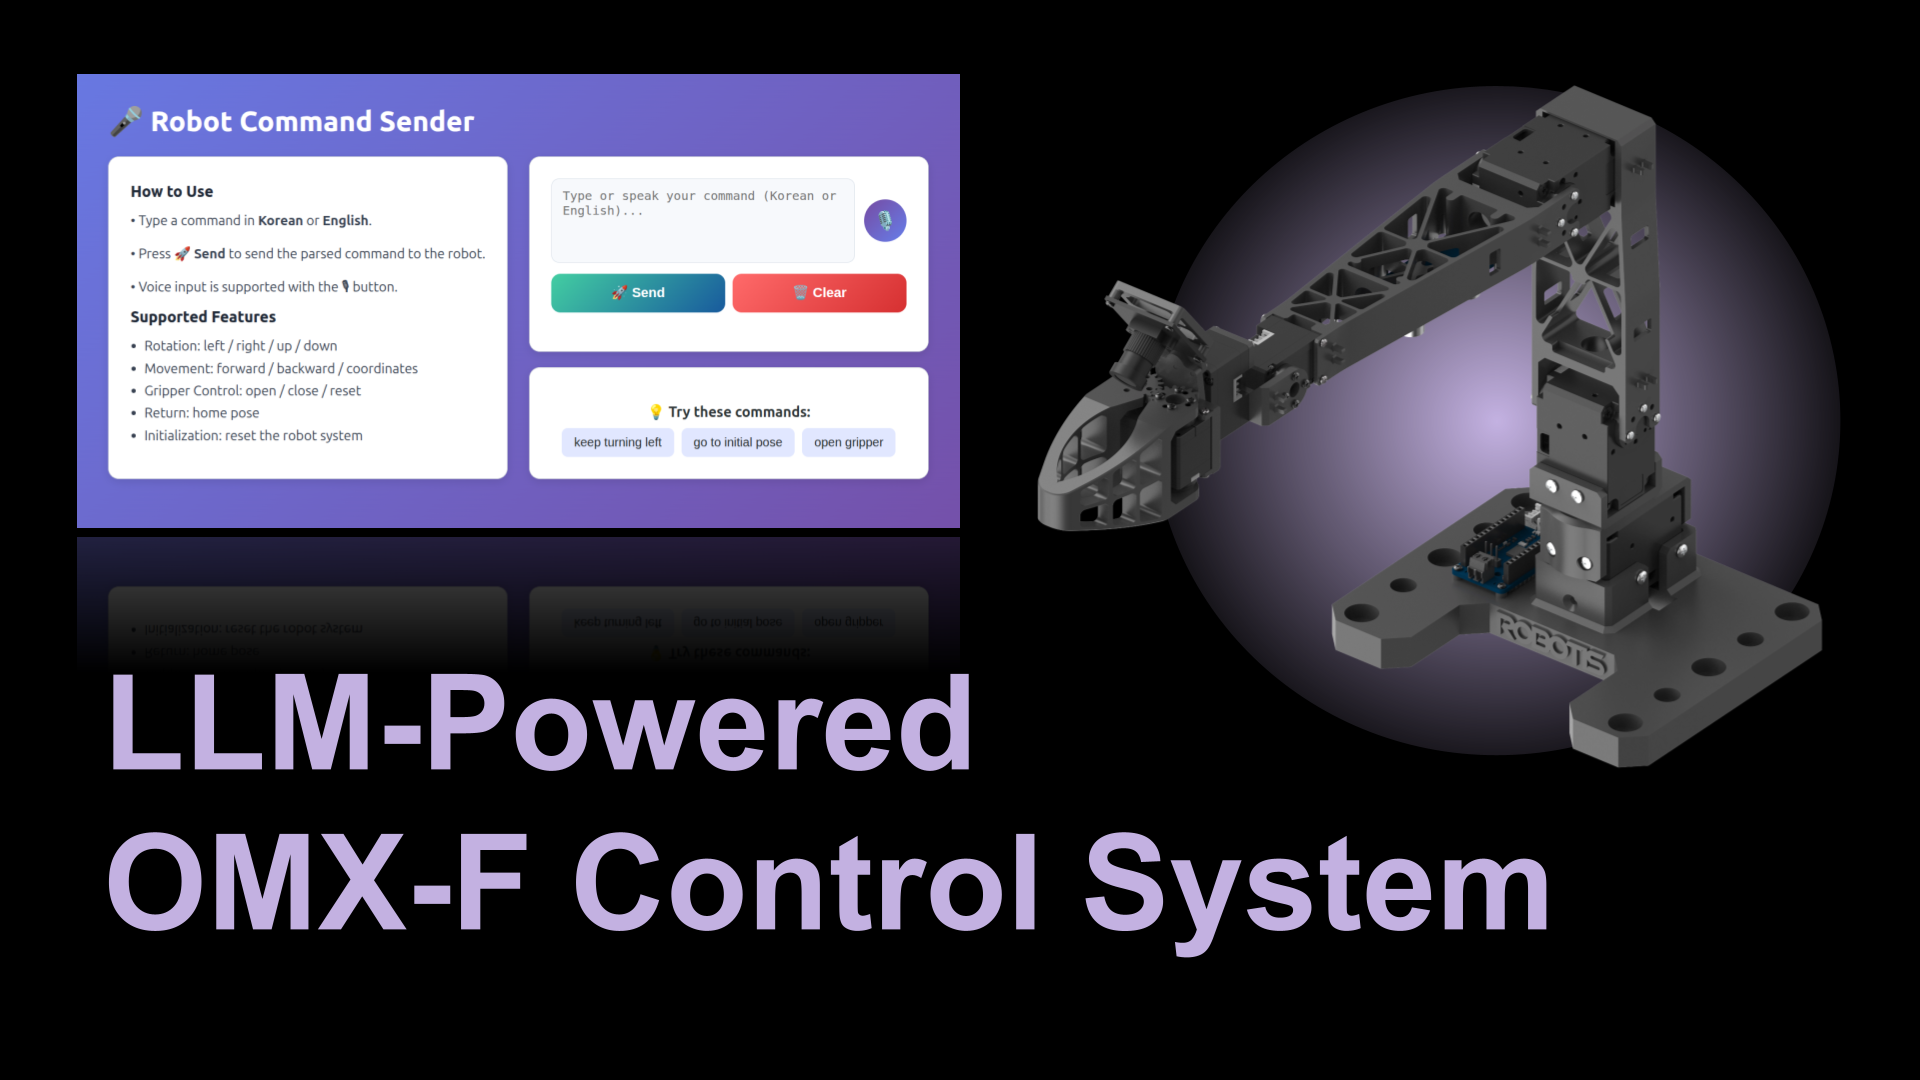
Natural Language-Based OMX Control System [Code]
2025.08 - 2025.10
- Implemented a rule-based control system that enables the OMX robot to perform movements based on natural language commands.
- The system interprets user input and dynamically maps it to predefined motion rules, allowing intuitive human-robot interaction through textual instructions.
ROS 2GazeboPythonNatural Language ProcessingOMX Control
OMX GUI & Keyboard Teleoperation System [Docs]
2025.10
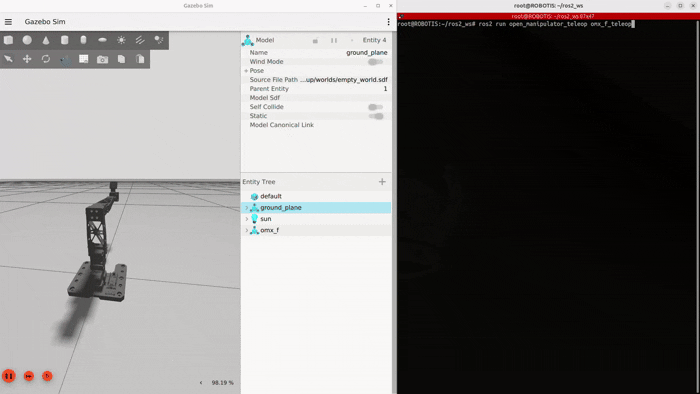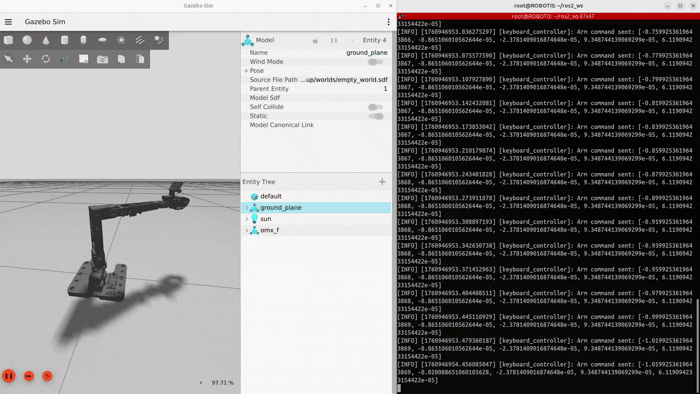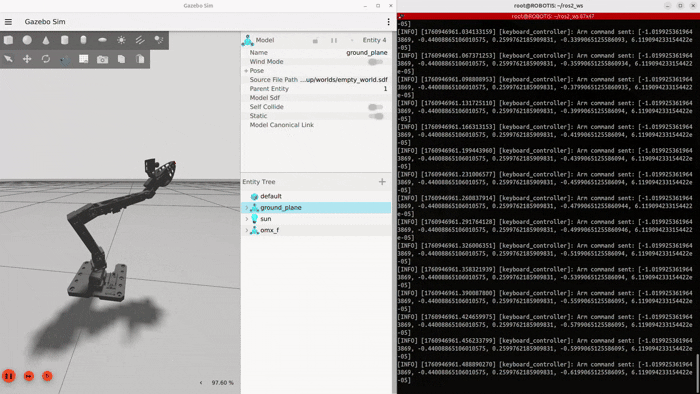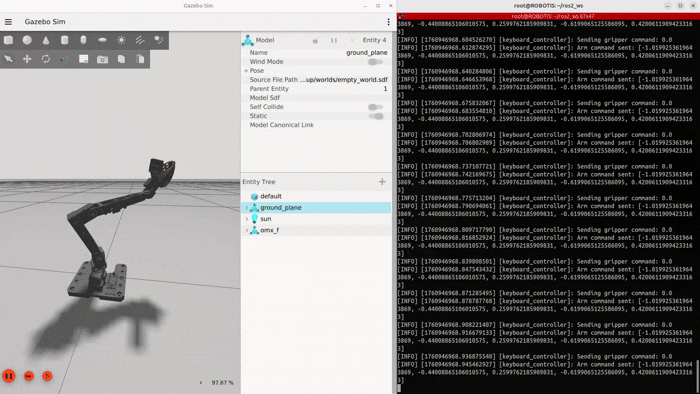
- Developed a MoveIt-based graphical user interface to control the OMX robot and implemented keyboard teleoperation functionality for real-time manual control.
- This system allows both visual and direct control methods for precise robot manipulation.
ROS 2MoveItQtKeyboard TeleoperationRobot Control
Assistive System for the Visually Impaired [Code]
2025.03 - 2025.06
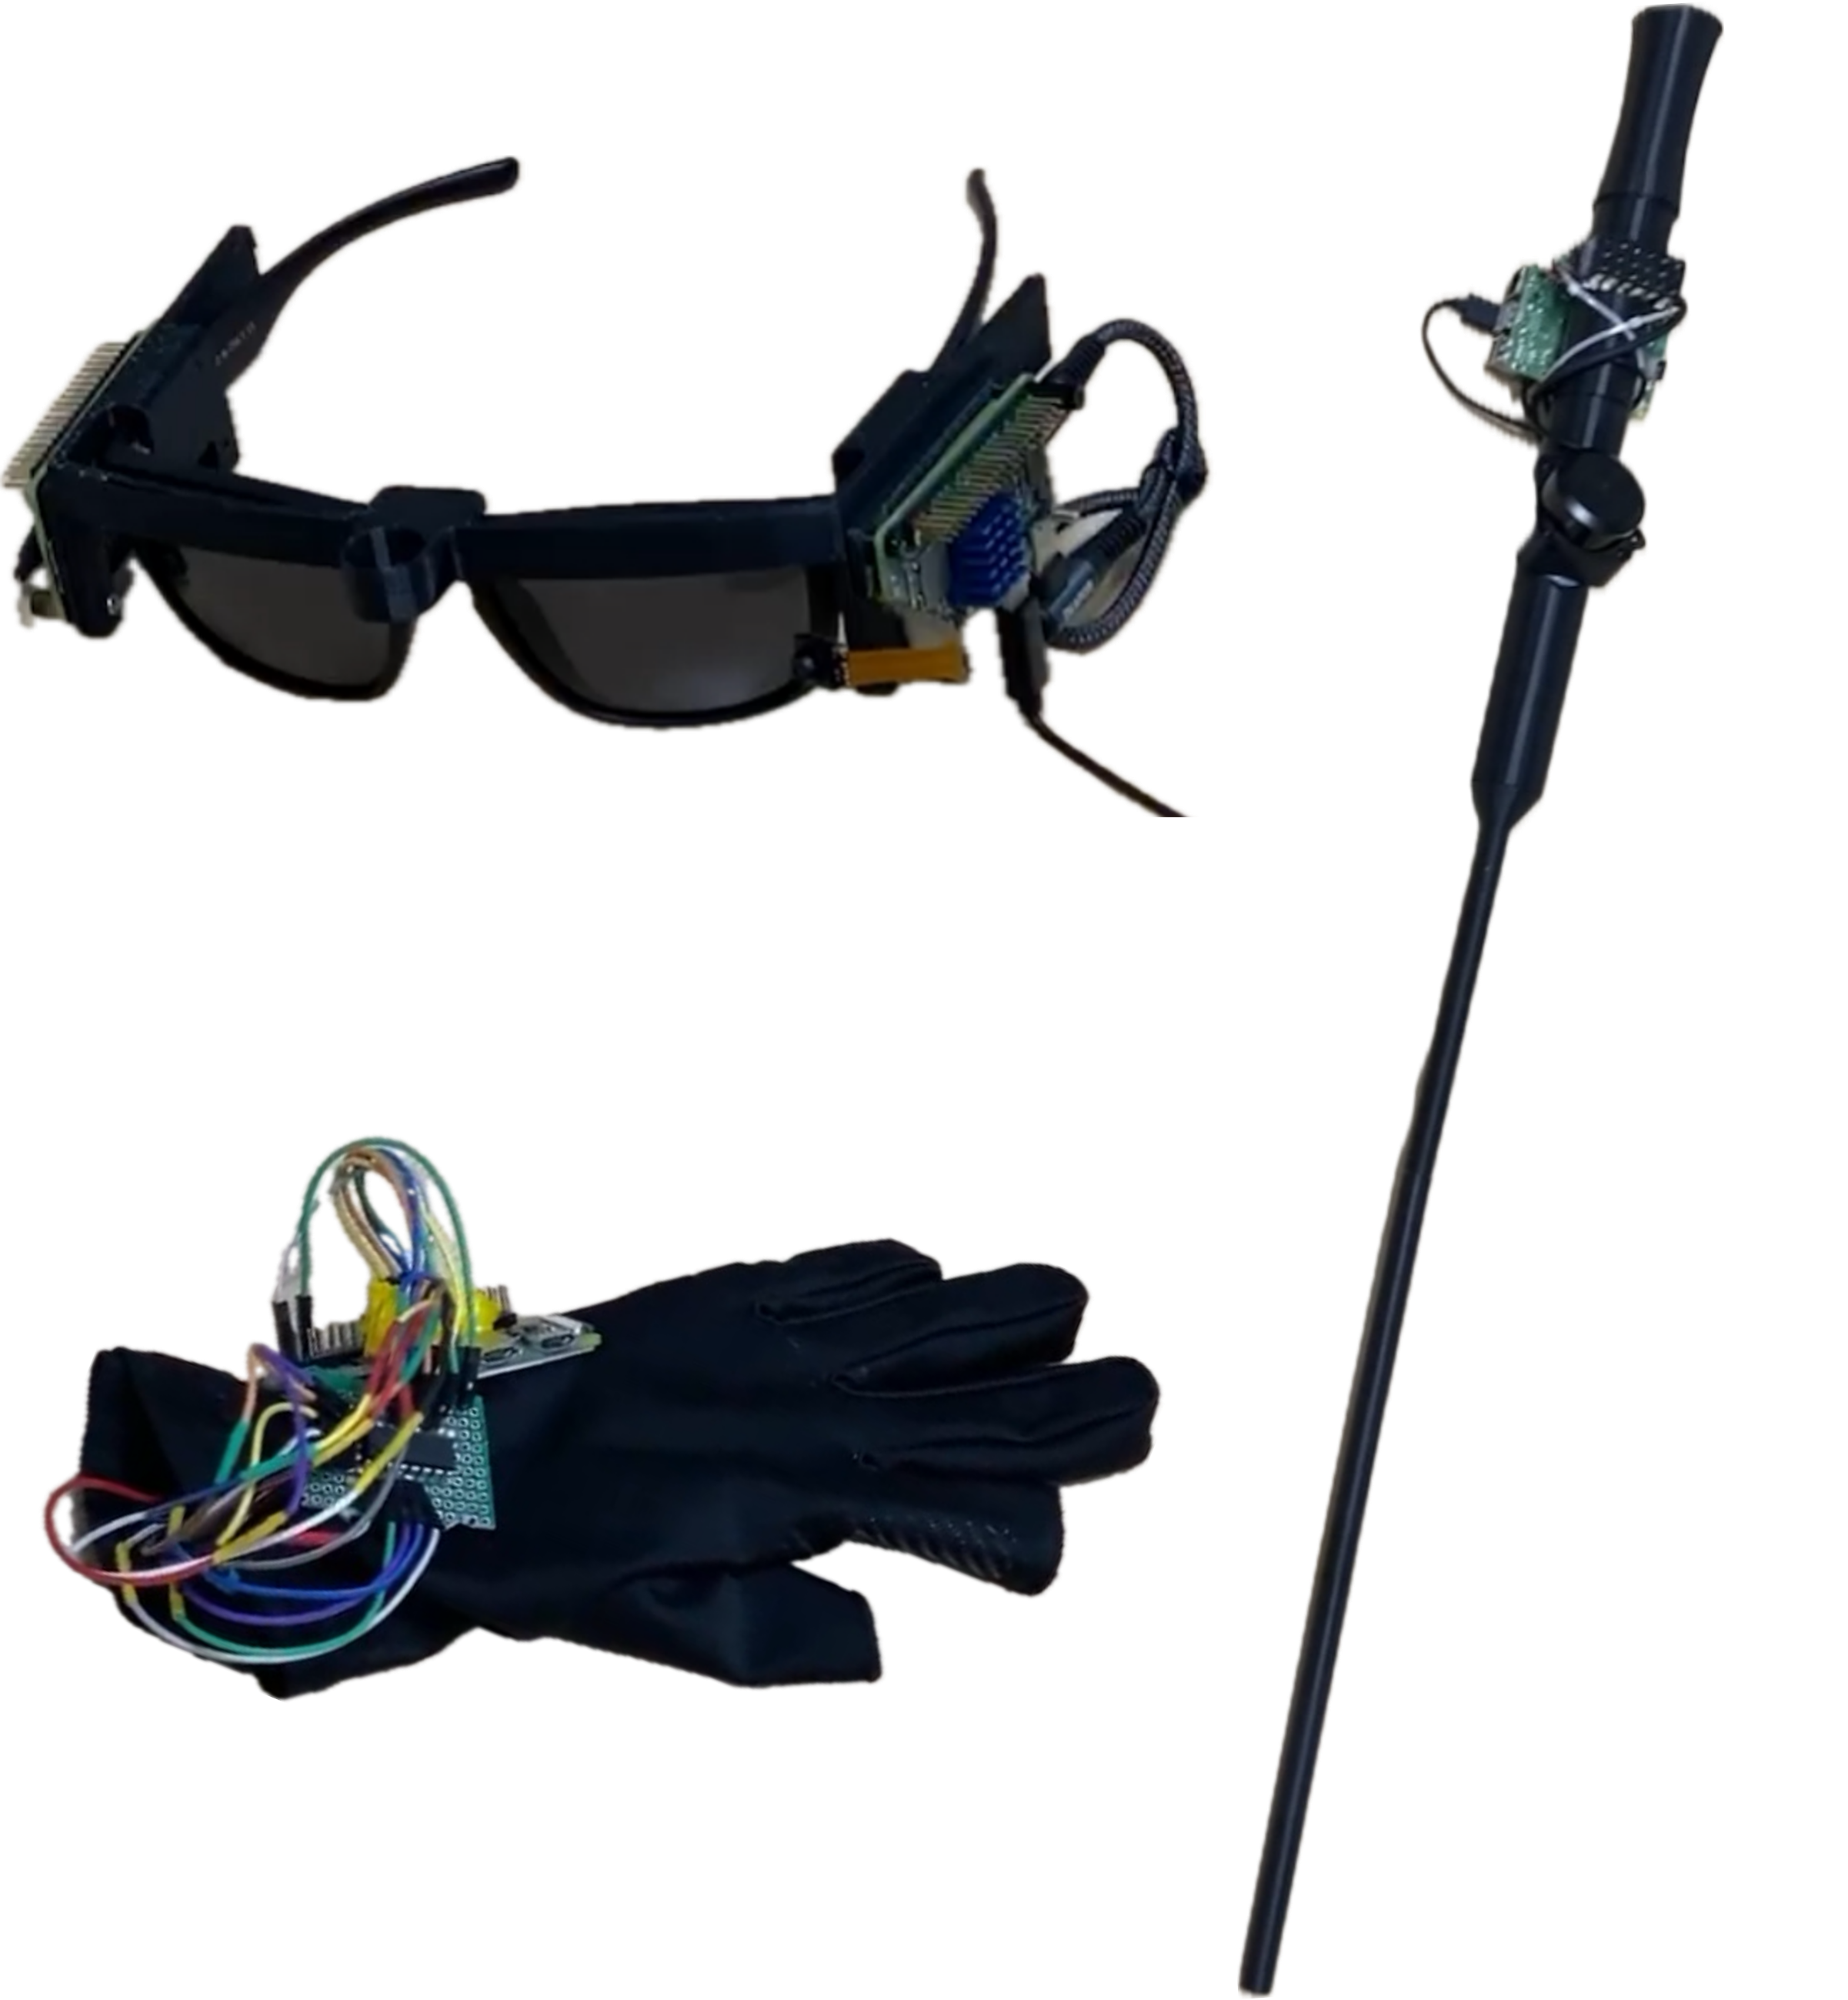
- Designed and implemented an on-device assistive system consisting of smart glasses, a smart cane, and a smart glove to enhance safe navigation for visually impaired users.
- The system detects road obstacles in real-time and provides guidance through voice feedback or braille output.
ROS 2YOLOOn-device AIObject DetectionEmbedded Systems
Portable Battery Rental System Using Temi Robot [Video]
2025.03 - 2025.06
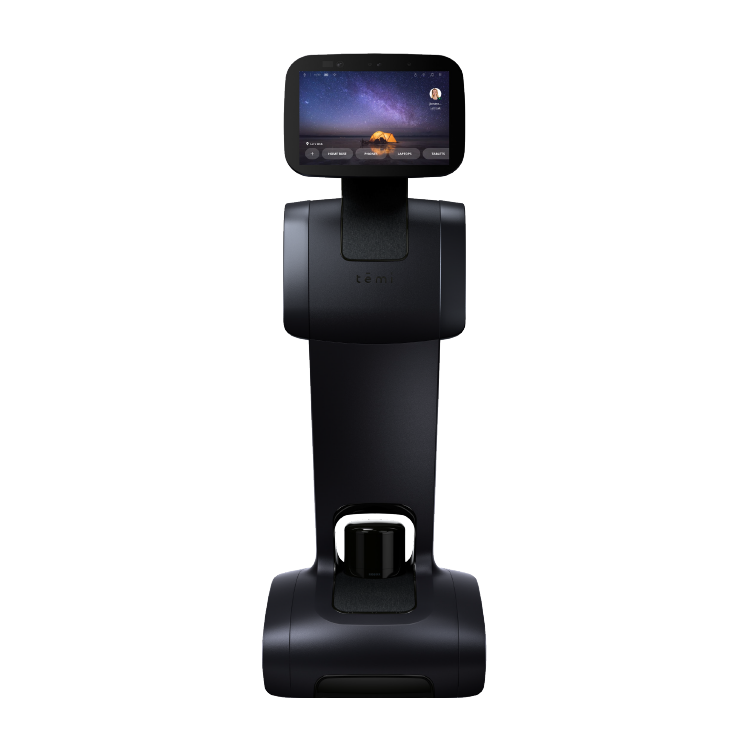
- Developed an autonomous battery rental system using the Temi robot, capable of monitoring real-time battery levels and available inventory.
- The robot navigates autonomously to deliver portable batteries to users, integrating mobile application control and real-time database synchronization.
JavaScriptFirebaseAndroid Development
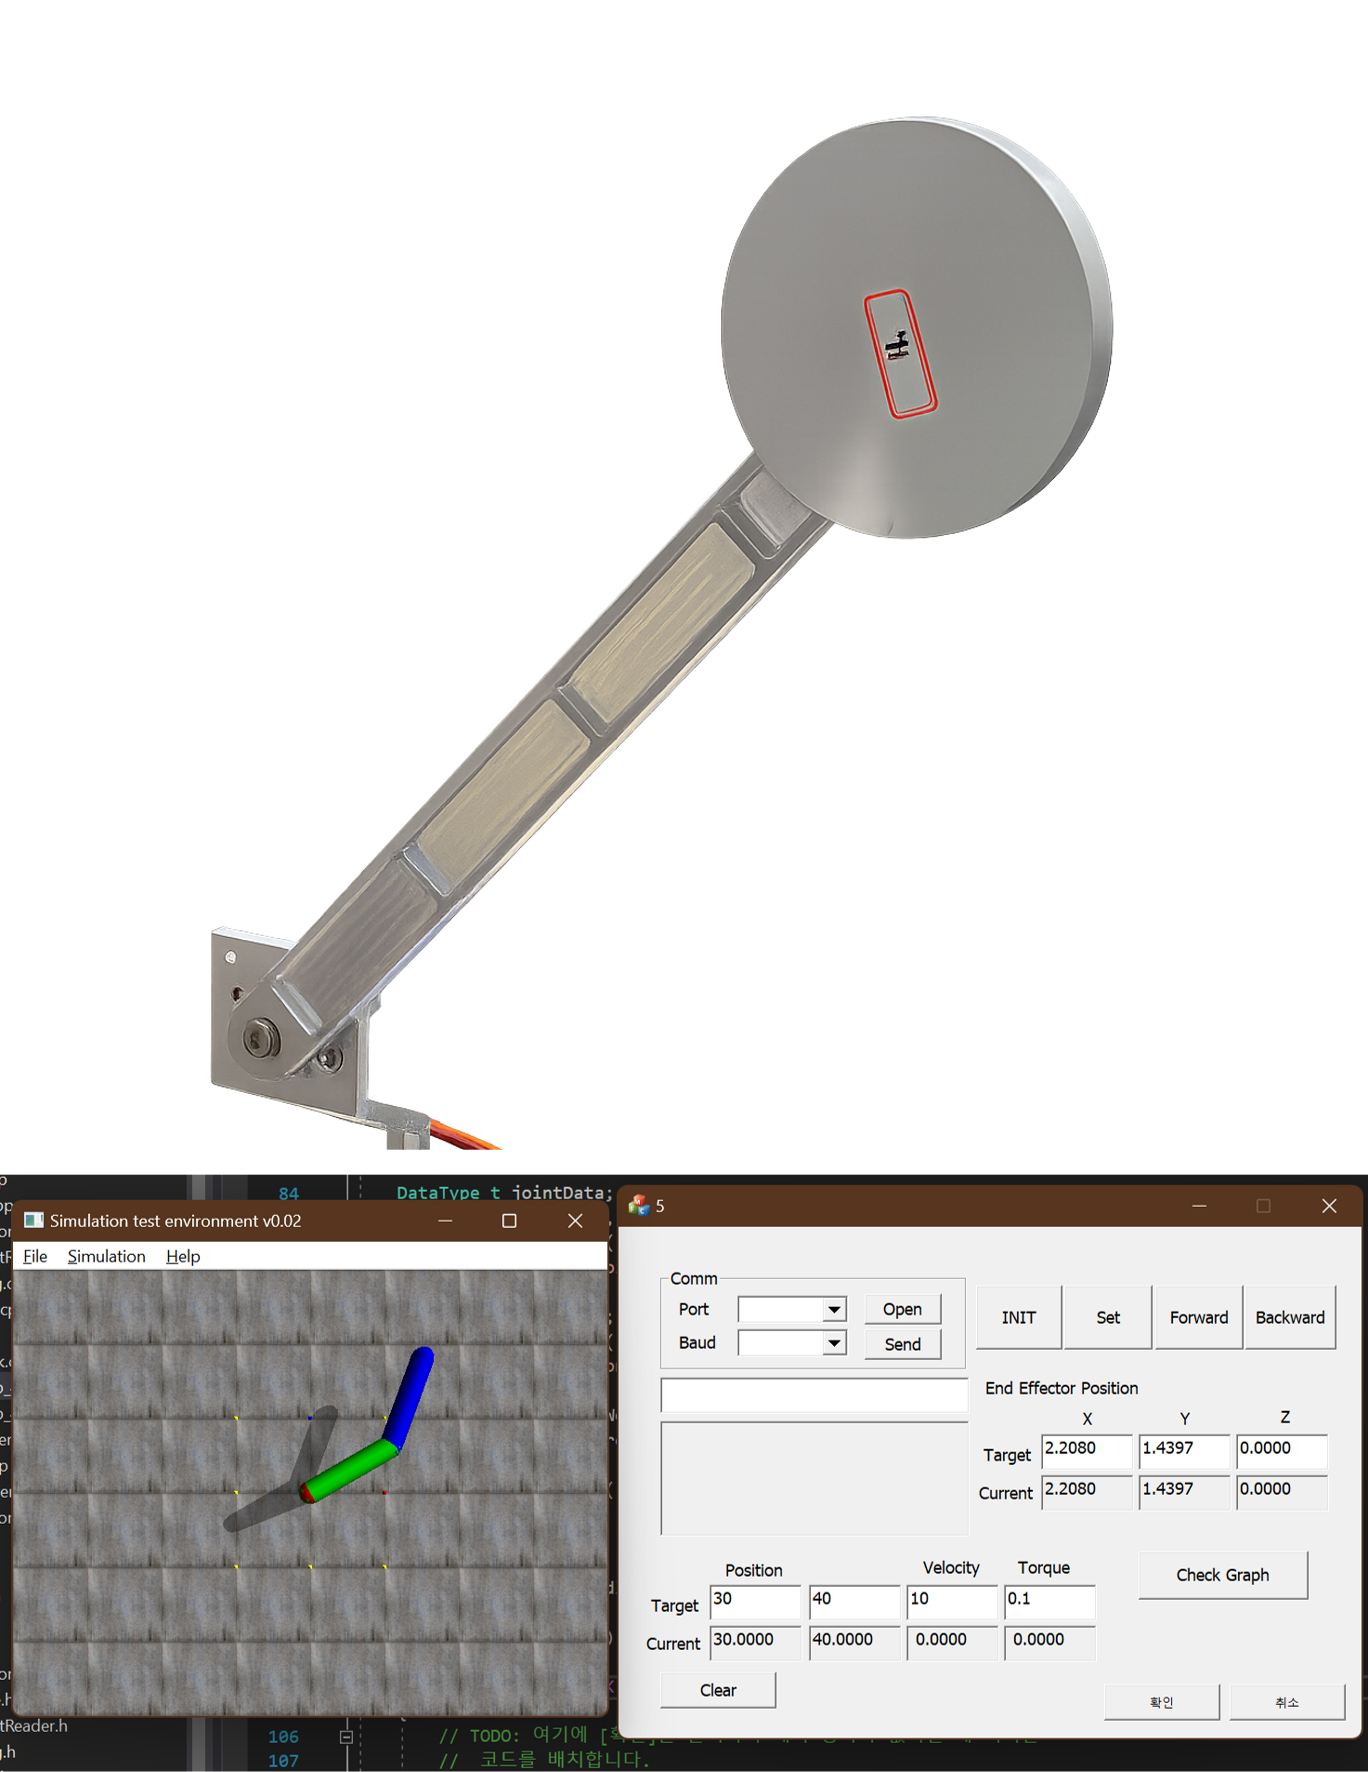
2-DOF Robotic Arm Control & GUI Development [Code]
2024.09 - 2024.12
- Designed and controlled a 2-DOF robotic arm through simulation and GUI-based interaction.
- The project focused on understanding and implementing forward and inverse kinematics, enabling precise control and visualization of robotic motion through mathematical modeling.
Forward KinematicsInverse KinematicsODE (Ordinary Differential Equations)QtRobot Simulation
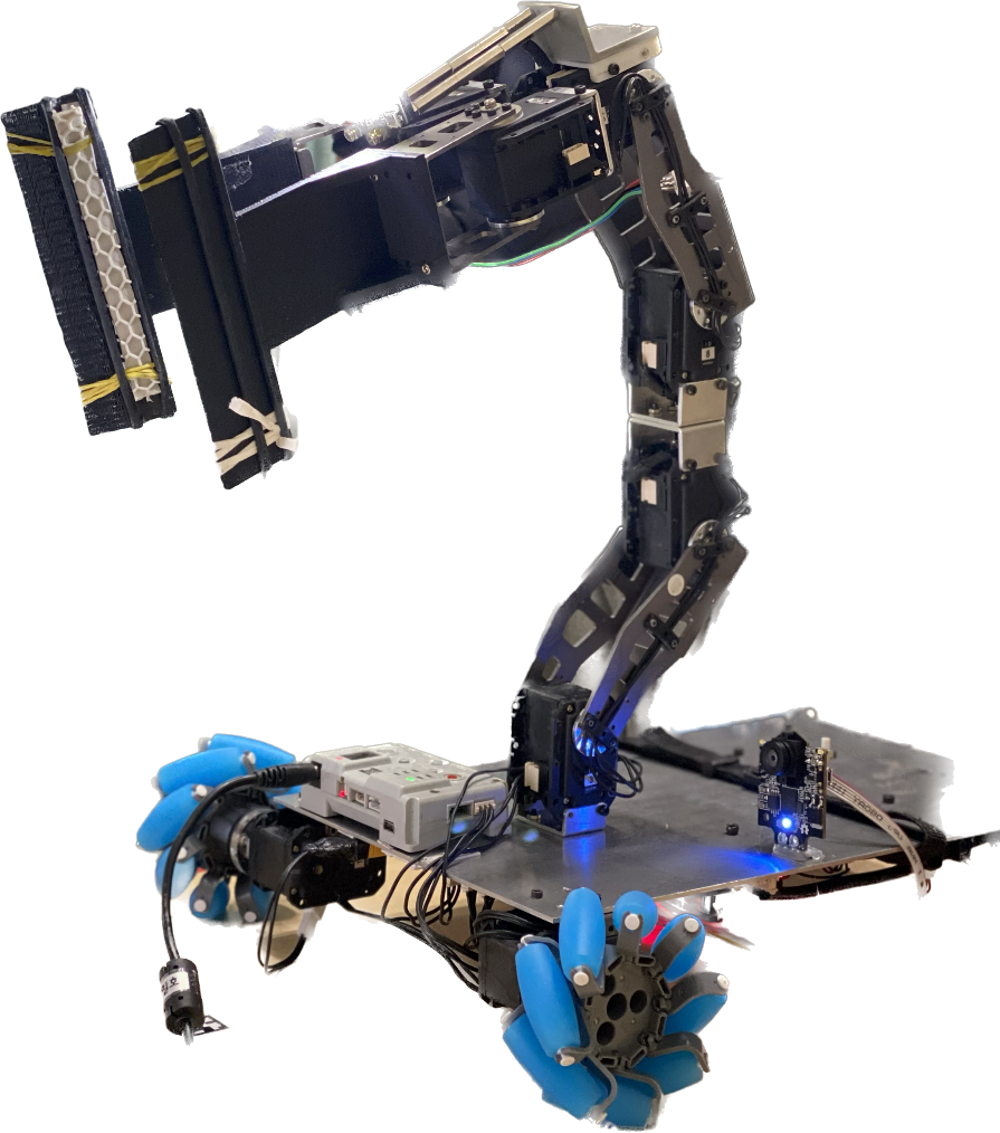
ROBOOK: Autonomous Book Picking Robot [Video]
2022.09 - 2022.12
- Developed a 6-DOF autonomous robot capable of identifying specific books via QR code recognition and transporting them to a designated checkout area.
- The robot utilizes Dynamixel motors and mecanum wheels for precise omnidirectional movement and object manipulation.
ArduinoDynamixel ControlMecanum WheelsQR Code RecognitionEmbedded Systems